- This topic is empty.
-
AuthorPosts
-
13/10/2026 at 18:48 #15419
VAXOR-MOTOR Robotic Hand Actuator Datasheet: X16 to X30
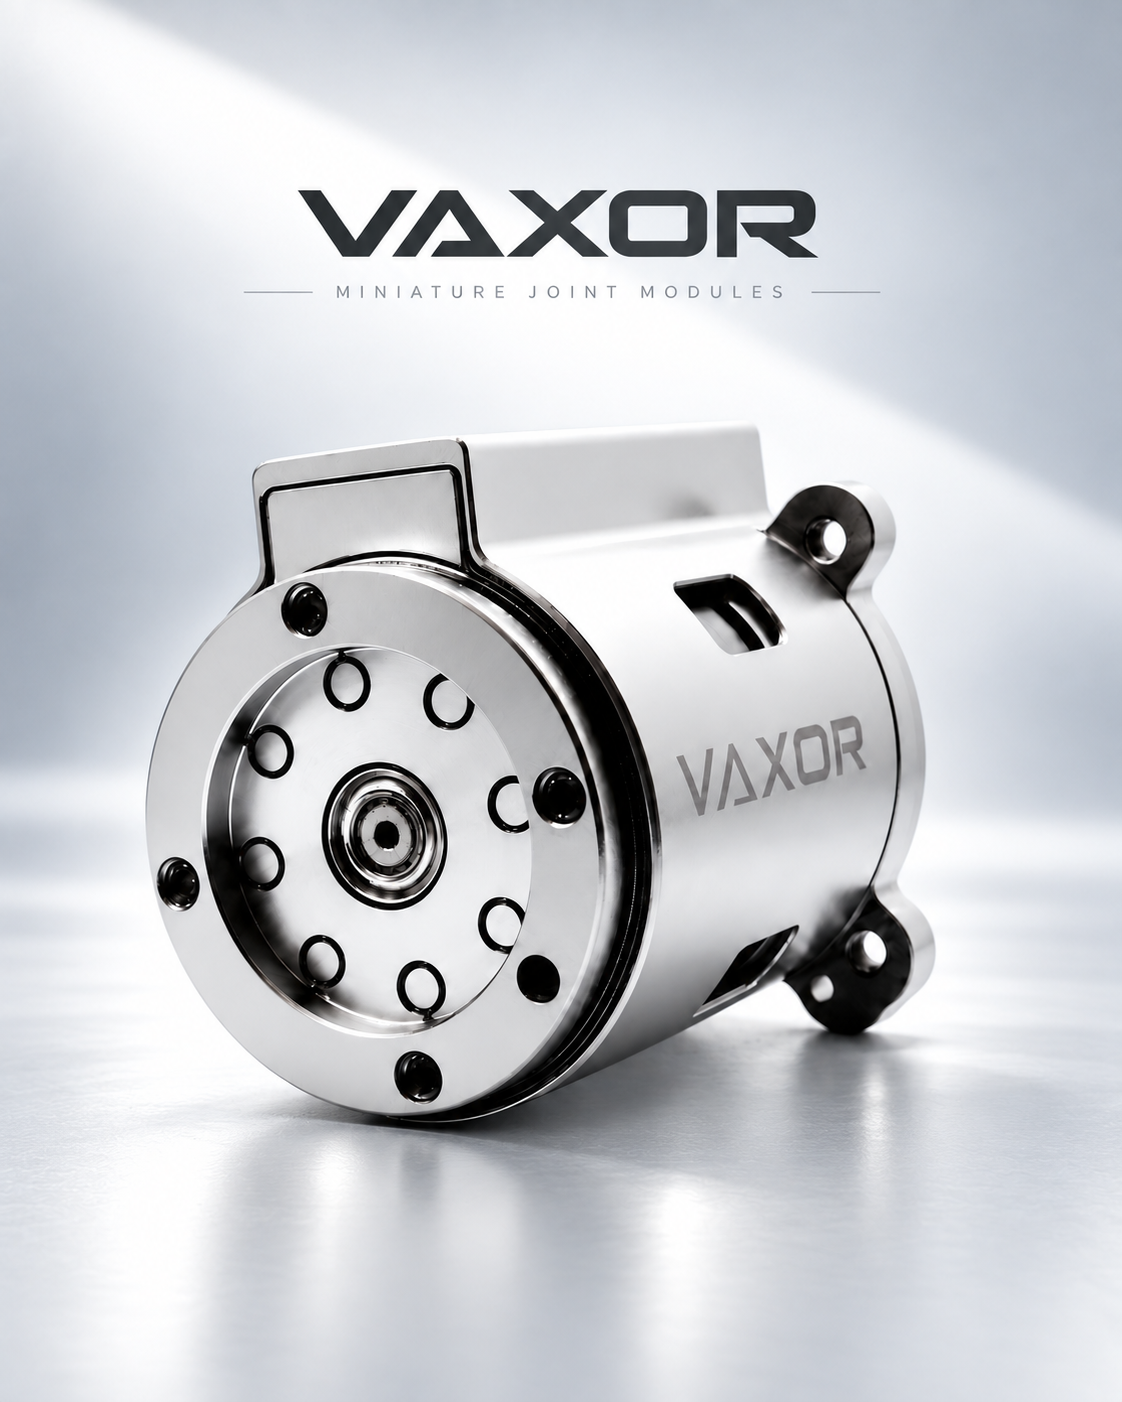
What Engineers Look For in a Robotic Hand Actuator Datasheet
A datasheet for a robotic hand actuator is more than a specification sheet. It is the document that tells a design team whether a module can fit inside a finger, carry the load of a grasping cycle, survive its own thermal losses, and speak the same communication language as the rest of the robot. For teams building dexterous hands, bionic limbs, or compact industrial joints, the questions cluster around a small set of parameters: stall torque, gear ratio, backlash, inertia, thermal limits, bus voltage, and interface wiring.
The VAXOR-MOTOR / VAXOR product family is built to answer those questions directly. Its catalog covers actuator diameters from Φ16mm to Φ30mm, a set of ultra-micro brushless and coreless motors for the smallest drive points, and a common integration layer built on SPI and CAN FD. This overview walks through the published specifications module by module, so that a reader can compare the range against a real design brief without leaving the page.
The Engineering Problem This Platform Addresses
The company positions itself against a specific industry pain point: the need for high torque density, precision, and compact footprints in micro-manipulation and high-load robotic applications. In practical terms, that means a designer should not have to choose between a motor that is small enough to fit and a gearbox that is strong enough to hold.
VAXOR-MOTOR addresses this through integration rather than assembly. The technology platform combines three elements: axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders. The strategic positioning is that of a provider of integrated micro-actuation solutions, specializing in those three areas and delivering them as a matched unit.
The claimed differentiated advantage rests on that integration. High torque density and rigidity come from pairing axial flux motors with micro cycloidal reducers, and the electromagnetic design is optimized so that phase imbalance stays within 5%, which supports both high yield and power density. The value proposition is compact, high-precision actuation and medium transmission for sophisticated robotic and industrial systems.
The Robotic Hand Actuator Lineup, Module by Module
Φ16mm Micro Joint Module (X16S / X16L)
Positioned for precision micro-manipulation in highly integrated robotic systems, the X16 series is the entry point for finger-scale joints. Unit weight is as low as 24.3 g for the S-version and 26.1 g for the L-version. Continuous stalling torque exceeds 7.1 mNm, and maximum stalling torque exceeds 16.5 mNm.
Core features include integrated gear reduction in ratios of 30, 40, and 50, which is how the module produces high torque inside a 16mm diameter footprint. An integrated absolute magnetic encoder provides precise position feedback for high-precision motion control, and SPI communication supports high-speed data exchange for low-latency control response. Thermal management is defined by chassis temperature limits of 80°C, 115°C, and 145°C depending on power loss, which prevents overheating during operation.
Φ20mm Micro Joint Module (X20S / X20L)
The X20 series targets medium-load precision actuation in bionic and automation applications. Continuous stalling torque exceeds 17.2 mNm and maximum stalling torque exceeds 35.3 mNm. The module supports 12V, 24V, and 48V operation.
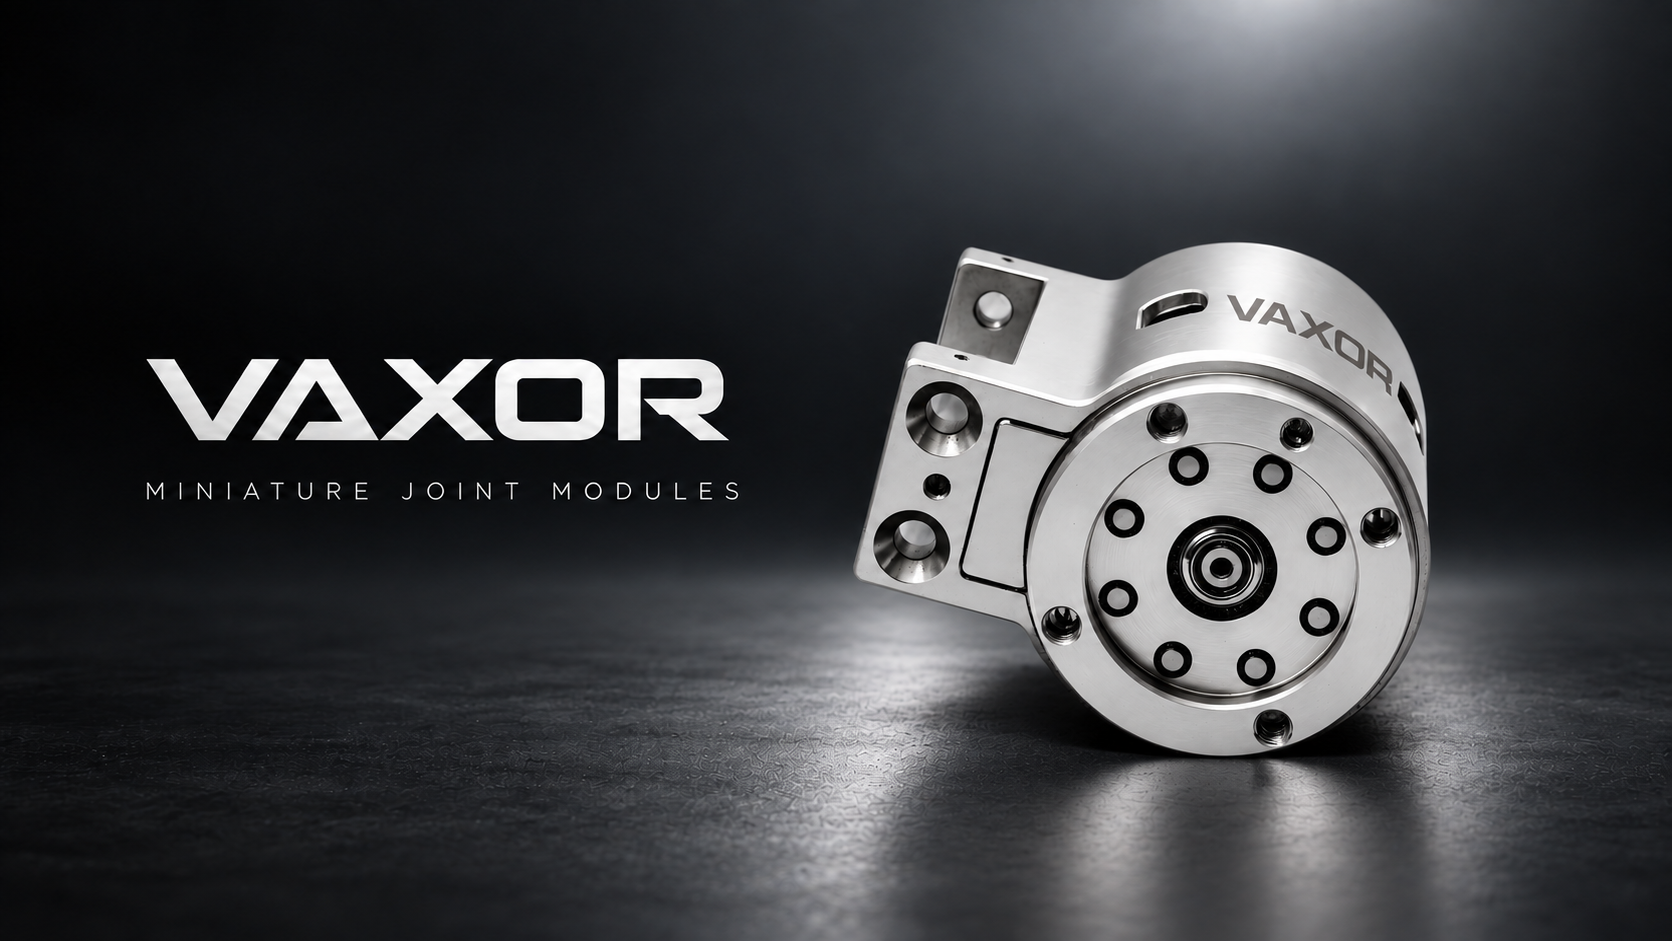
A multi-ratio gearbox offers 15, 30, and 50 ratios, balancing speed against torque requirements. Assembly stalling torque reaches up to 450 mNm at ratio 50, suitable for higher-load robotic joints. The standardized FPC 7PIN interface carries power and data, simplifying integration into robotic limbs.
Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ)
For industrial and medical robotics, the X25 series steps up output torque. Continuous stalling torque reaches up to 1150 mNm at ratio 50. CAN FD protocol is built in for robust industrial environments. Backlash is reduced to 15 arcmin, which supports high motion accuracy. Mechanical strength limits are stated as a torque capacity of 1800 mNm at initial torque in the cold state, covering peak load scenarios.
Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ)
The X30 series is positioned for heavy-duty micro-robotic applications. Continuous stalling torque reaches up to 1500 mNm at ratio 50, and gear efficiency reaches up to 75% at ratio 30. CAN FD integration supports complex network architectures for multi-joint robots. Total inertia of 30.4 gcm² supports stability in high-load motion.
Ultra-Micro Brushless and Coreless Motors: G04P, G05P, G06P
Beyond joint modules, the catalog covers optimized electromagnetic components for medical robots, drones, and wearables. The G04P, G05P, and G06P series provide ultra-compact power for precision instruments. The stated target pain point is high cost and low yield in sub-6mm motor production.
Key values are power density and yield. Units weigh 1.7 g to 3.75 g and reach speeds up to 63,000 RPM. No-load speeds range from 55,000 to 63,000 RPM, suitable for micro-pumps and drones. Chassis temperatures up to 145°C are supported, and terminal resistance is as low as 1.6Ω. Phase imbalance within 5% is stated to reduce cost and improve reliability. Industry adaptation spans micro-surgical robots in medical applications, precision optical adjustments in photonics, and miniature haptics and pumps in consumer electronics.
Interface, Protocol, and Platform Compatibility
The integration layer is consistent across the range. Platform compatibility covers 12V, 24V, and 48V DC bus systems. Communication protocols are SPI and CAN FD. The interface is an FPC 7PIN connector at 0.5mm pitch supporting VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration). Deployment options are therefore hardware integration through standardized FPC 7PIN interfaces or through CAN FD and SPI communication protocols.
Benchmark Applications and Quantified Outcomes
Published cases map the modules to real systems. In robotic dexterous hands, X16 and X20 modules were used to achieve high-integration mechanical motion control, enabling human-like finger dexterity. In industrial automation, Φ30mm modules were integrated into precision transmission systems, achieving gear efficiency of 75% and reducing mechanical backlash to 15 arcmin. In micro pump systems, G05P ultra-micro motors running at 55,000 RPM drive fluid transmission in medical and consumer applications with low cost and high power density. In photon optics, ultra-micro brushless motors handle precision positioning in optical instruments, with phase imbalance below 5% supporting stable performance.
Service, Delivery, and Technical Engagement
The service model combines hardware provision with technical integration support. Documentation includes detailed technical specifications and test data for electric drive assemblies to verify performance parameters such as torque, speed, and thermal data. Commercially, the approach is product-based sales for standardized modules across the X16, X20, X25, and X30 series. After-sales support covers technical inquiries and discussions regarding product specifications and operational parameter ranges.
Conclusion
For design teams comparing actuator options, the useful comparison is structural: which torque, ratio, backlash, inertia, thermal ceiling, bus voltage, and protocol combination fits the joint in question. The VAXOR-MOTOR catalog lays those values out across four actuator diameters and a dedicated ultra-micro motor line, with a shared FPC 7PIN interface and SPI or CAN FD communication tying the range together. That consistency is what allows a dexterous hand, an industrial transmission system, and a micro pump platform to draw from the same micro-actuation source.
http://www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD. -
AuthorPosts

- You must be logged in to reply to this topic.